Problem
What needed to be understood or measured
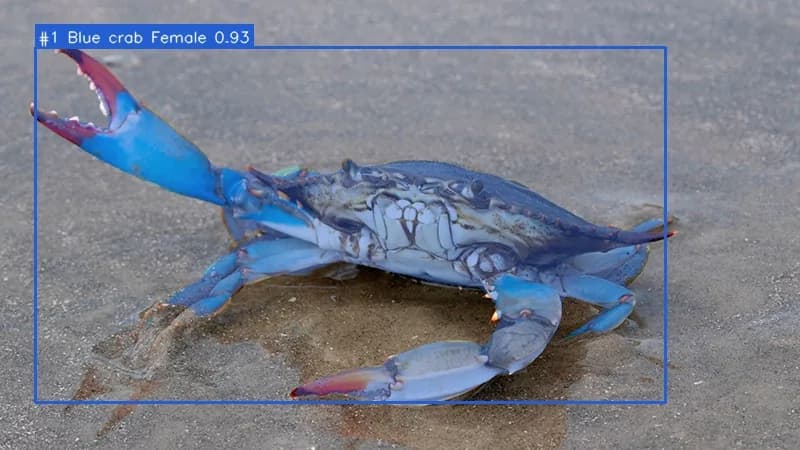
Marine monitoring needs both animal identification and physical dimensions; segmentation alone provides outlines in pixels, not measurements.
My contribution
My contribution
I developed this independent project, including dataset documentation, training configuration, inference code, examples, and a geometry-based measurement extension.
Experimental setup
Data and setup
A 631-image, four-class dataset with separate train, validation, and test splits. The measurement path requires RGB-aligned metric depth and a calibrated intrinsic matrix.
Method
From input to interpretable output
YOLO11m-seg predicts per-instance masks. Valid mask pixels are back-projected using depth and intrinsics, then PCA axes define two projected whole-mask extents.
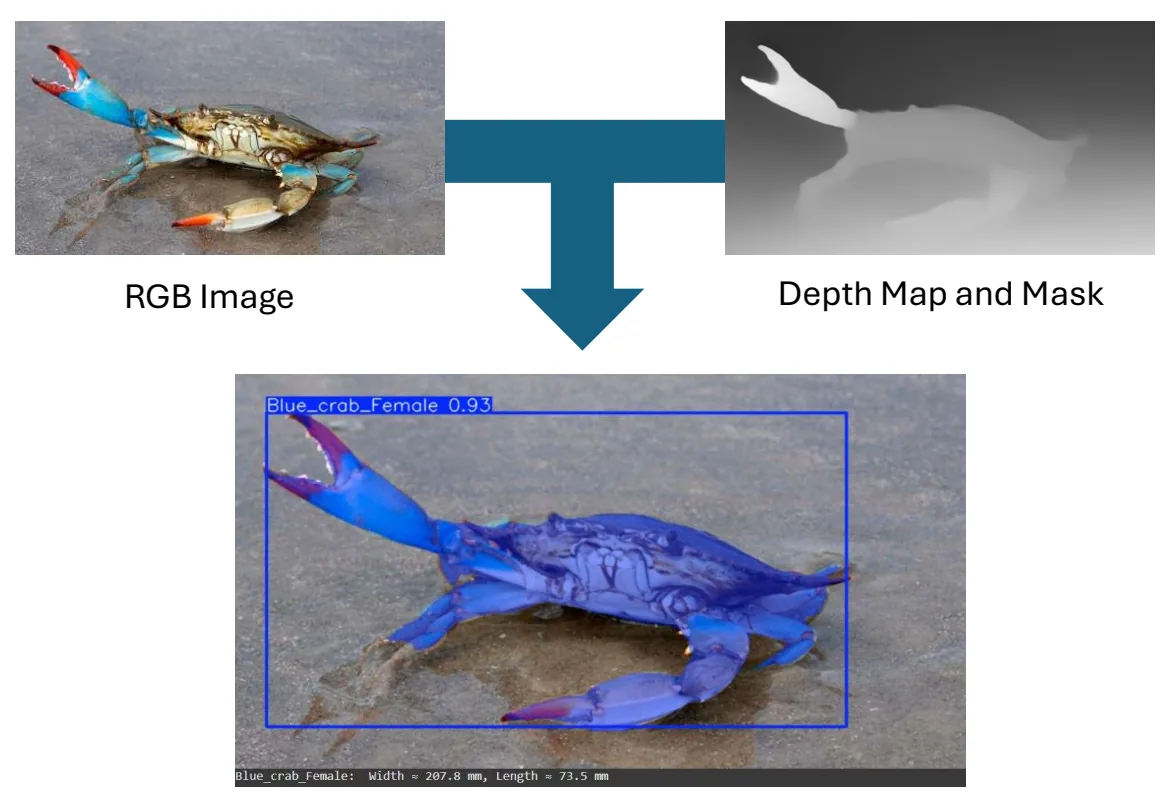 Open figure —
Measurement workflow from segmentation and depth to projected dimensions.
Blue_crabs repository.Results
Reported results
test mask mAP@50
26-image re-evaluation
test mask mAP@50–95
small held-out split
Validation & uncertainty
Reference and uncertainty checks
The saved model was re-evaluated on a 26-image test split in September 2026. The dimension demonstration itself has not been validated against physical reference measurements.
Limitations & failure modes
Operating limits and failure modes
 Open figure —
Demo frames retain missed detections and occlusions as visible failure cases.
Blue_crabs repository.Occluded limbs, changing pose, depth outliers, calibration error, refraction, sparse masks, and class imbalance affect both boundary quality and projected extents.
The physical accuracy of the dimension estimator is not established. It needs calibrated depth, underwater optical calibration, and comparison against reference measurements before measurement claims are justified.
Technical stack
Tools selected for the measurement chain
- Python
- YOLO11m-seg
- PyTorch
- OpenCV
- Depth imaging
- PCA geometry
Sources & project links
Papers and code
Public repository with dataset, checkpoint metadata, test re-evaluation, and explicit caveats around source-image licensing and metric validation.