Structural MonitoringPublished result
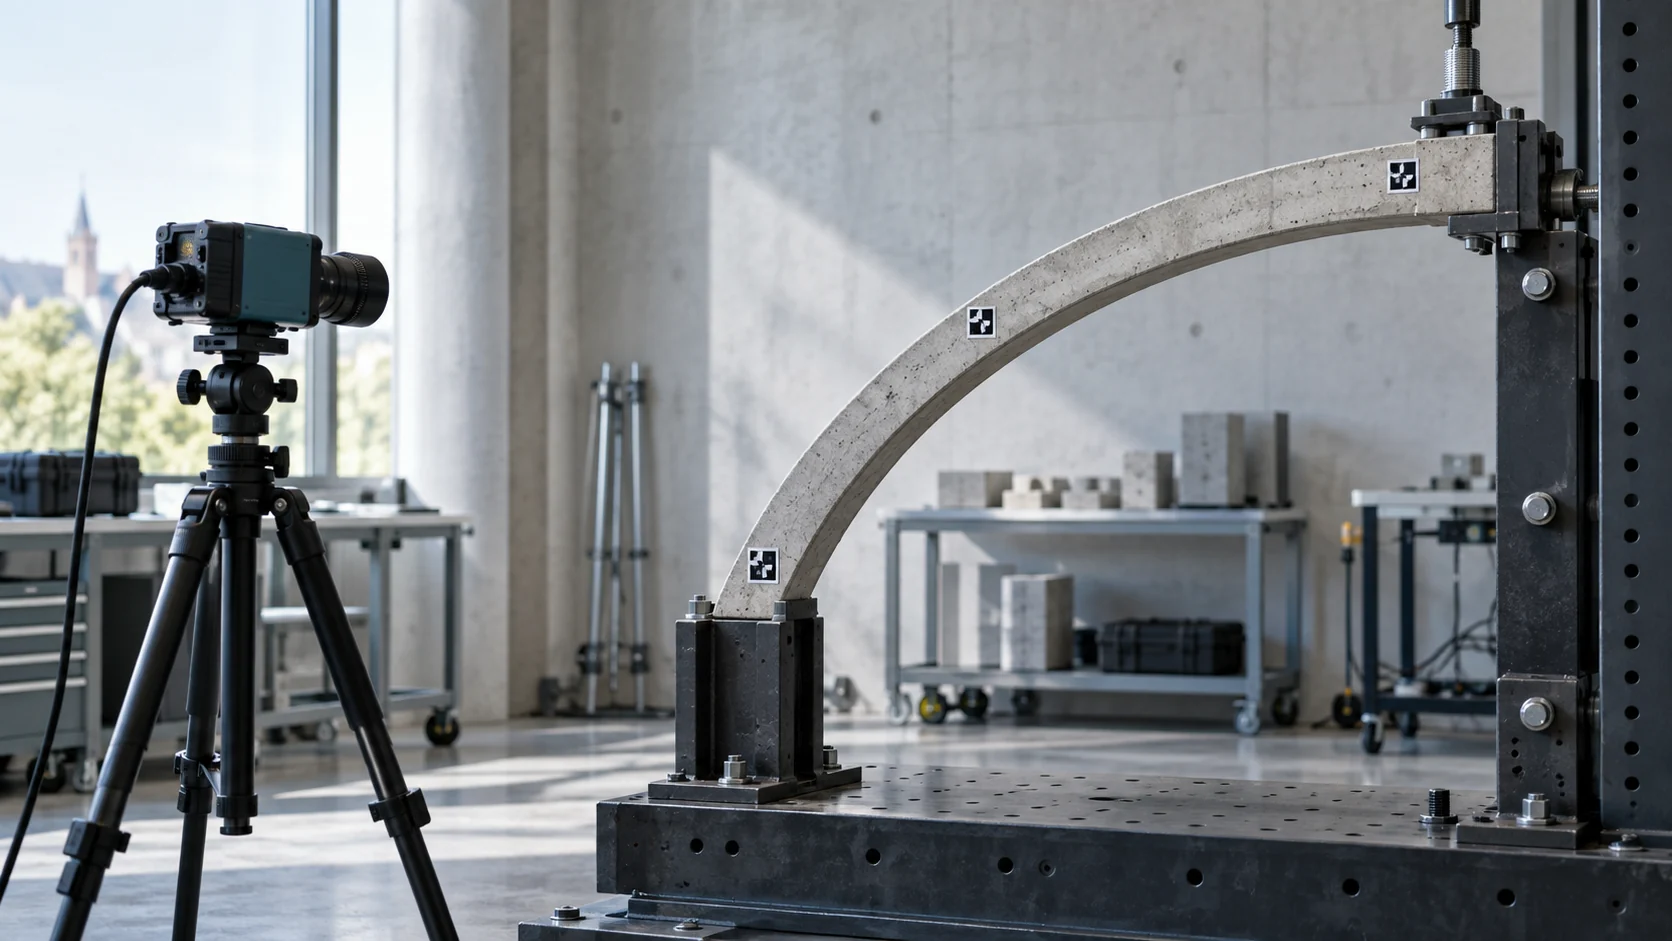
Infrastructure displacement monitoring
A low-cost marker pipeline for 6-DoF pose and displacement measurement, characterized against controlled reference motion and applied to structural experiments.
Arman Neyestani, PhD
Computer Vision Engineer & Researcher
I build and validate camera-based systems for structural inspection and displacement measurement, using calibration and reference data to connect image output with physical motion. My other work includes visual localization and environmental sensing.
Research Fellow · CeSMA, University of Naples Federico II
Camera geometry
Machine perception
Reference validation
Uncertainty
Selected work
Published studies, open datasets, and repository outputs are labelled with results, methods and clear limits, starting with my structural measurement work.
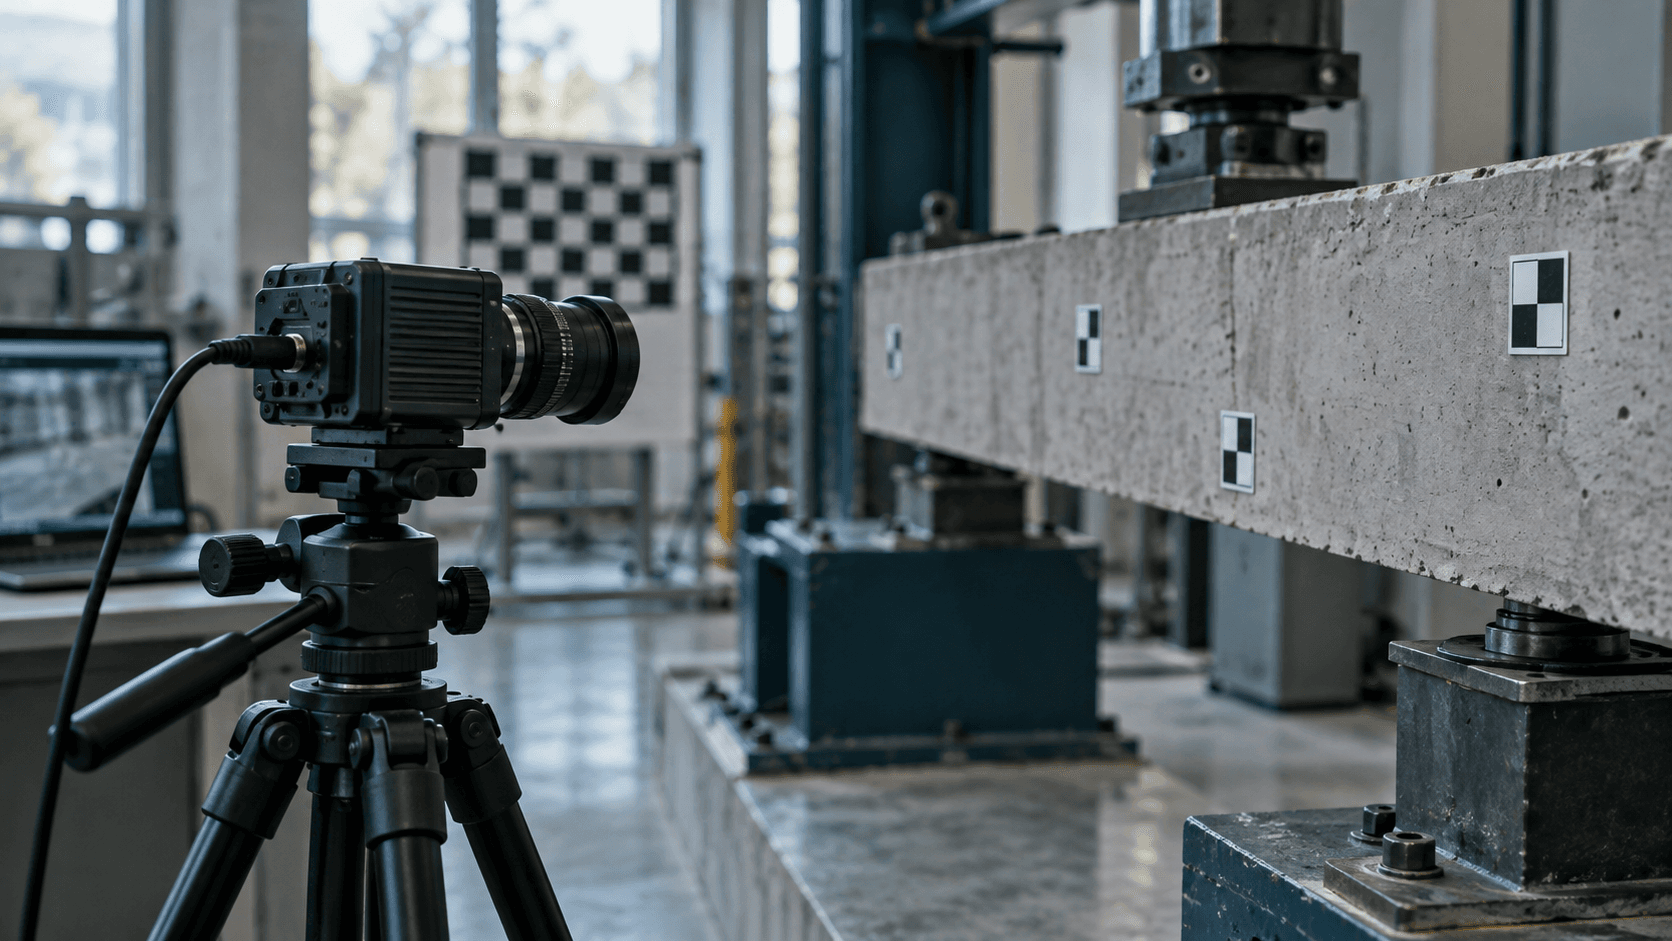
A low-cost marker pipeline for 6-DoF pose and displacement measurement, characterized against controlled reference motion and applied to structural experiments.
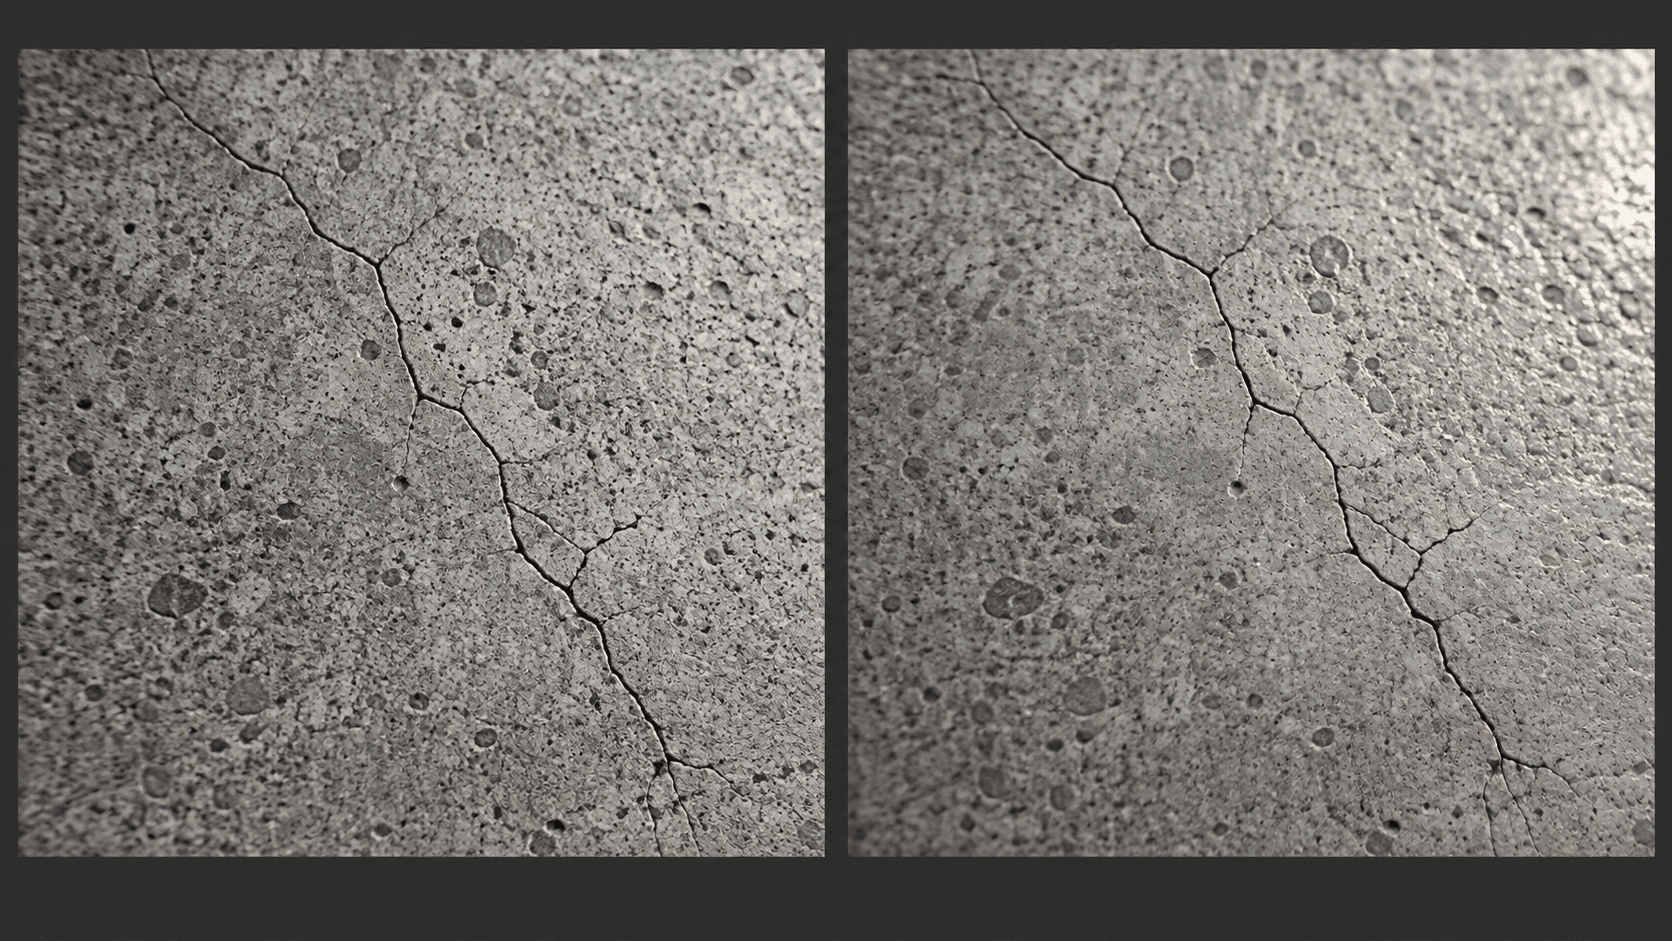
A shared ResNet-101 encoder learns a 128-dimensional embedding for deciding whether two images show the same crack pattern.
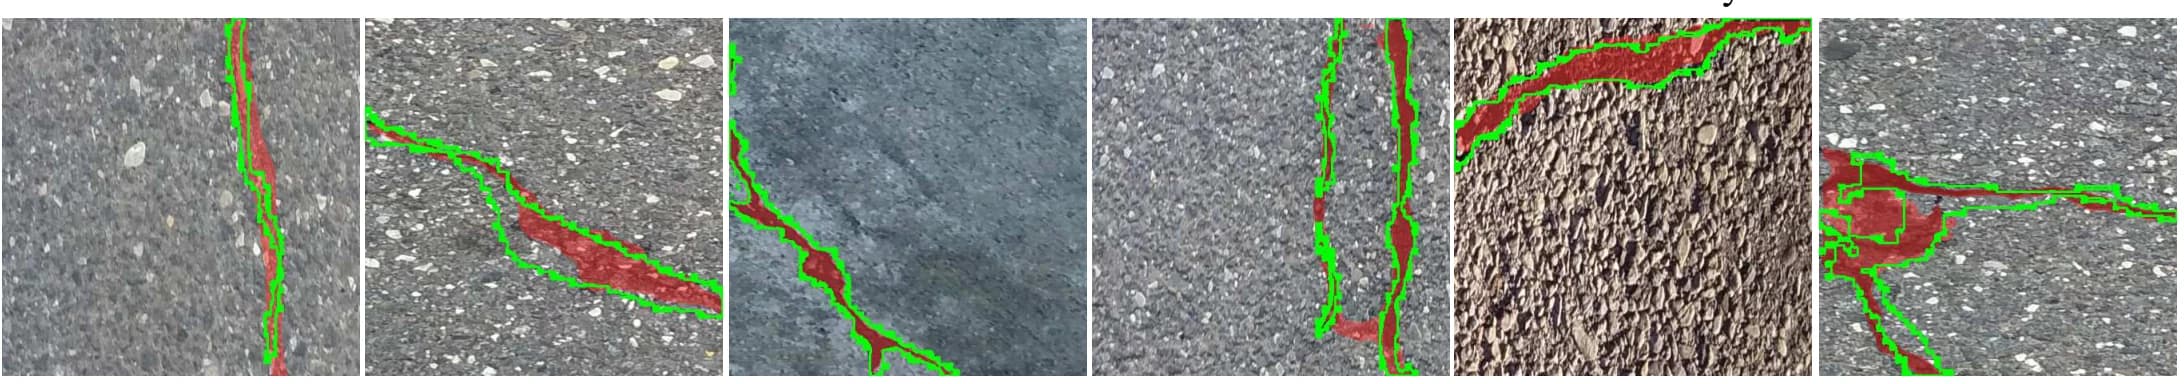
Pixel-level crack masks for civil-infrastructure inspection, developed around a YOLOv8 segmentation workflow and UAV-acquired imagery.
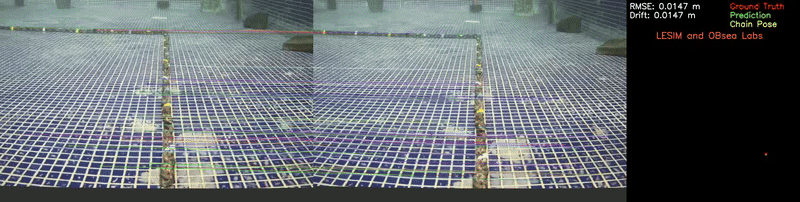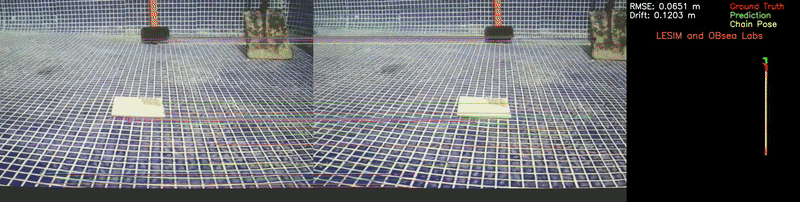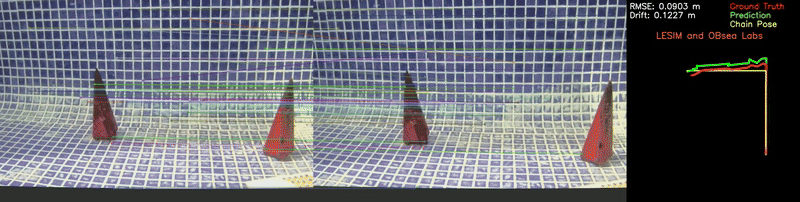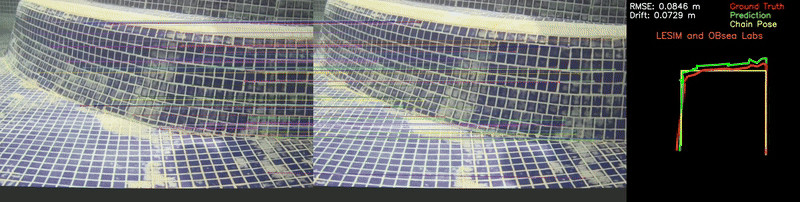
An open, calibrated underwater sequence with measured ground truth and a benchmark-oriented monocular visual-odometry pipeline.
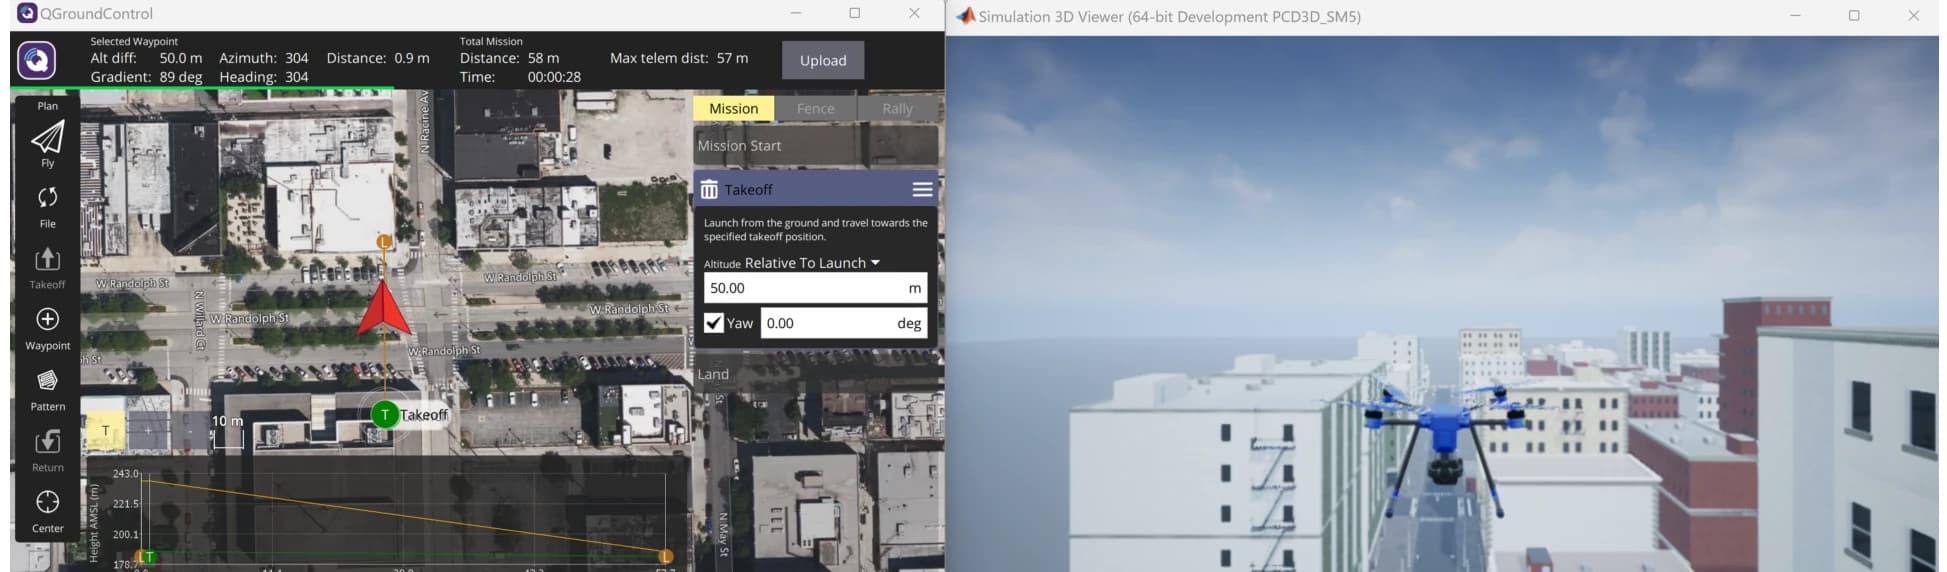
Monocular visual and visual-inertial localization studies that propagate feature, camera, attitude, and altitude uncertainty into UAV position estimates.
Core technical stack
Tools and methods I have applied across published studies and research prototypes.
More computer-vision work
Applied Vision · 2023
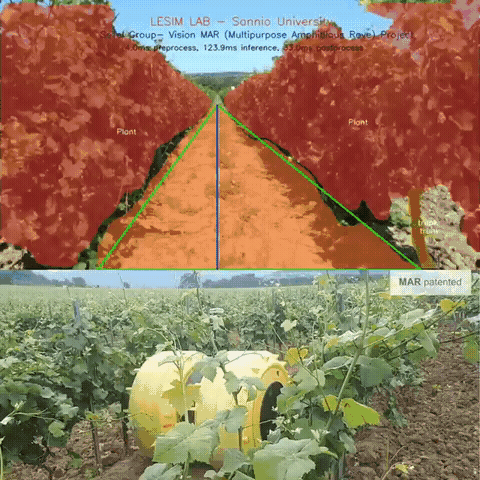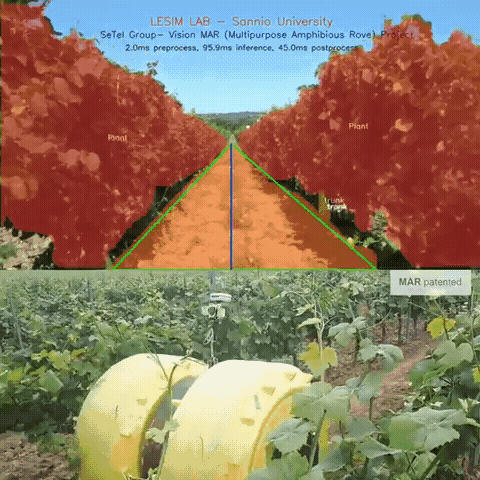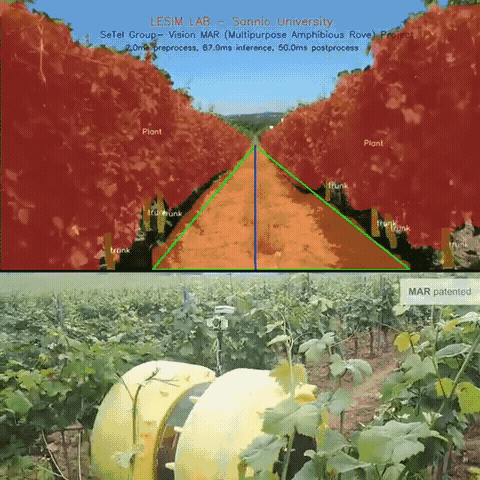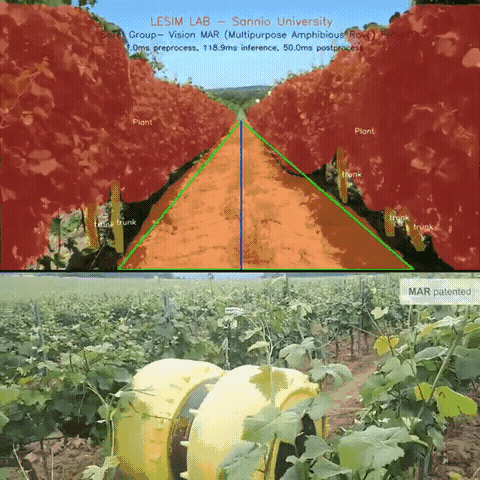
A four-class segmentation prototype converts orchard imagery into a visible soil corridor and image-space guidance signal for an amphibious rover.
↗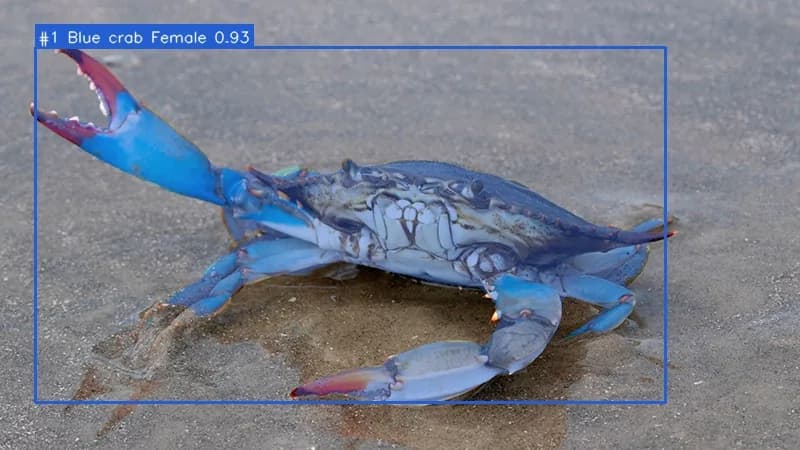
Applied Vision · 2025
Instance masks, aligned depth, and camera calibration are combined to estimate projected crab dimensions in millimeters.
↗
Environmental Sensing · 2024
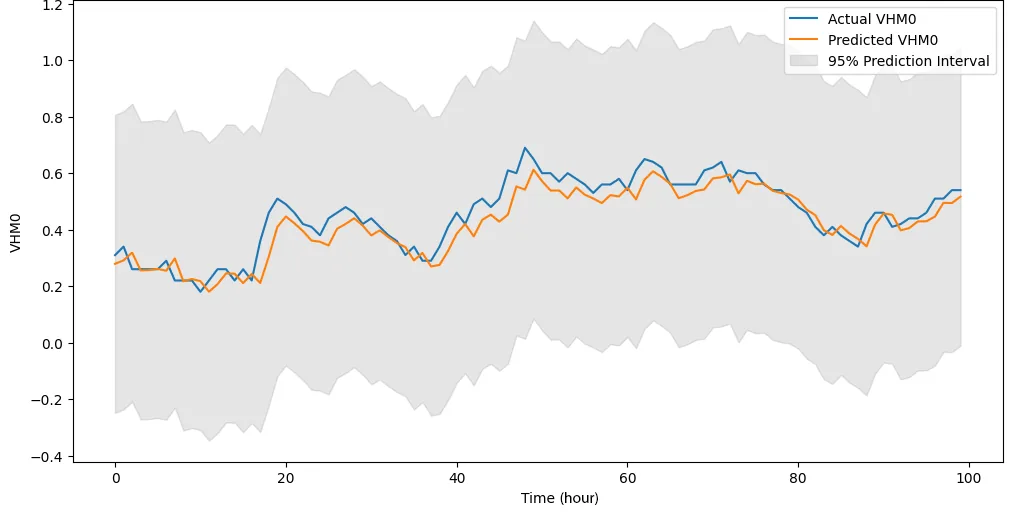
A GRU model turns 16-step marine observations into a one-step-ahead significant-wave-height estimate for digital-twin prototypes.
↗Working method
01 Frame the measurement problem.
02 Build the perception and geometry pipeline.
03 Compare against reference data.
04 Report uncertainty and failure modes.
Selected publications
Buildings 16(13), 2659
XXXIII International Scientific Conference Electronics (ET)
IEEE I2MTC
IEEE MetroSustainability
Open to the right problem