Problem
What needed to be understood or measured
Underwater imagery loses contrast and red wavelengths, making features less stable while ground-truthed datasets remain scarce.
My contribution
My contribution
I led the dataset and study as first author. During my UPC/OBSEA visiting appointment, I captured the controlled sequence and developed the feature-evaluation and monocular visual-odometry workflow with collaborators.
Experimental setup
Data and setup
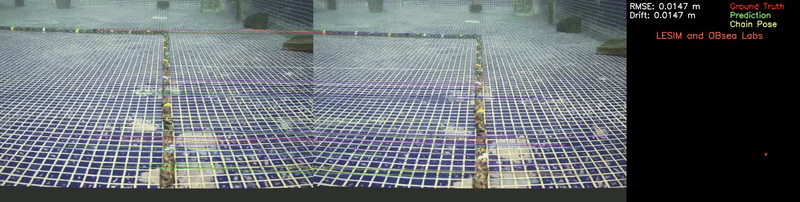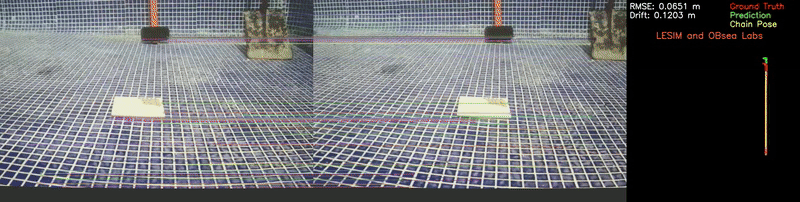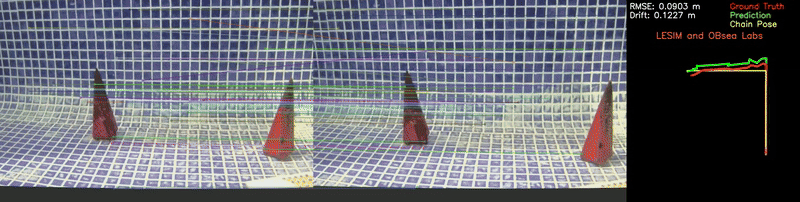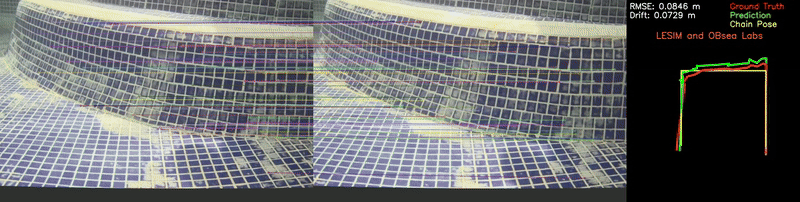
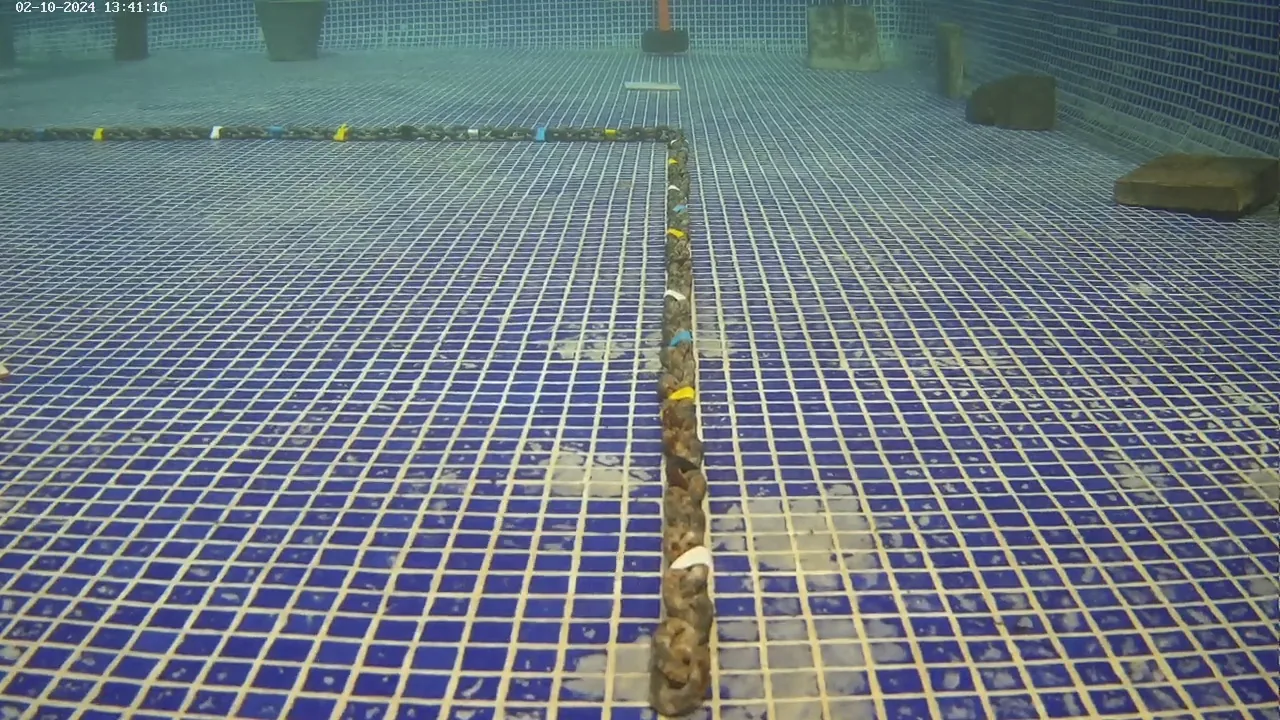
220 sequential 1280 × 720 frames in a 1.6 m deep indoor pool, captured by a tracked crawler along a measured 5.8 m X-Z path. Calibration and frame-aligned ground truth are public.
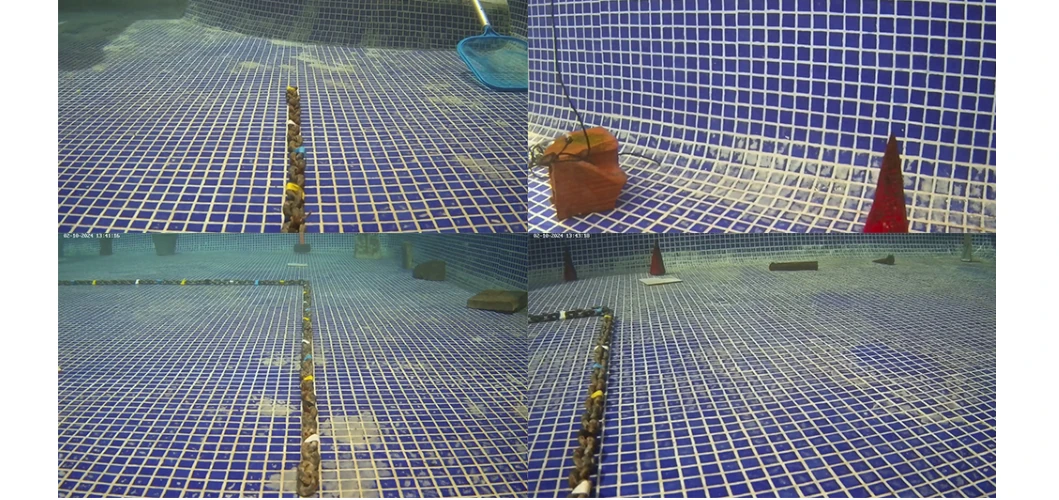 Open figure —
Representative views from the controlled SUBVO sequence.
SUBVO Dataset: Analyzing Feature Extraction for Underwater Monocular Visual Odometry, Fig. 1, p. 2.Method
From input to interpretable output
Color preprocessing, feature detection and matching, essential-matrix estimation, pose recovery, and genetic-algorithm tuning of the RANSAC threshold.
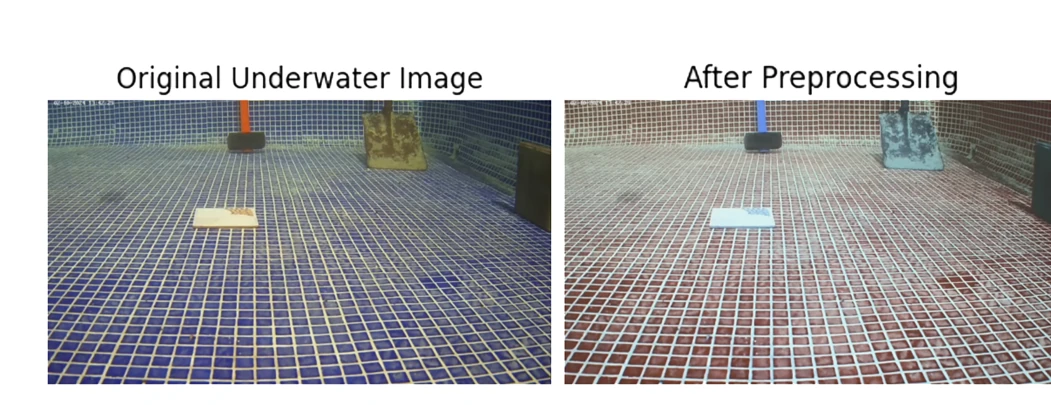 Open figure —
Original frame and the preprocessing result used to improve feature visibility.
SUBVO Dataset, Fig. 2, p. 2.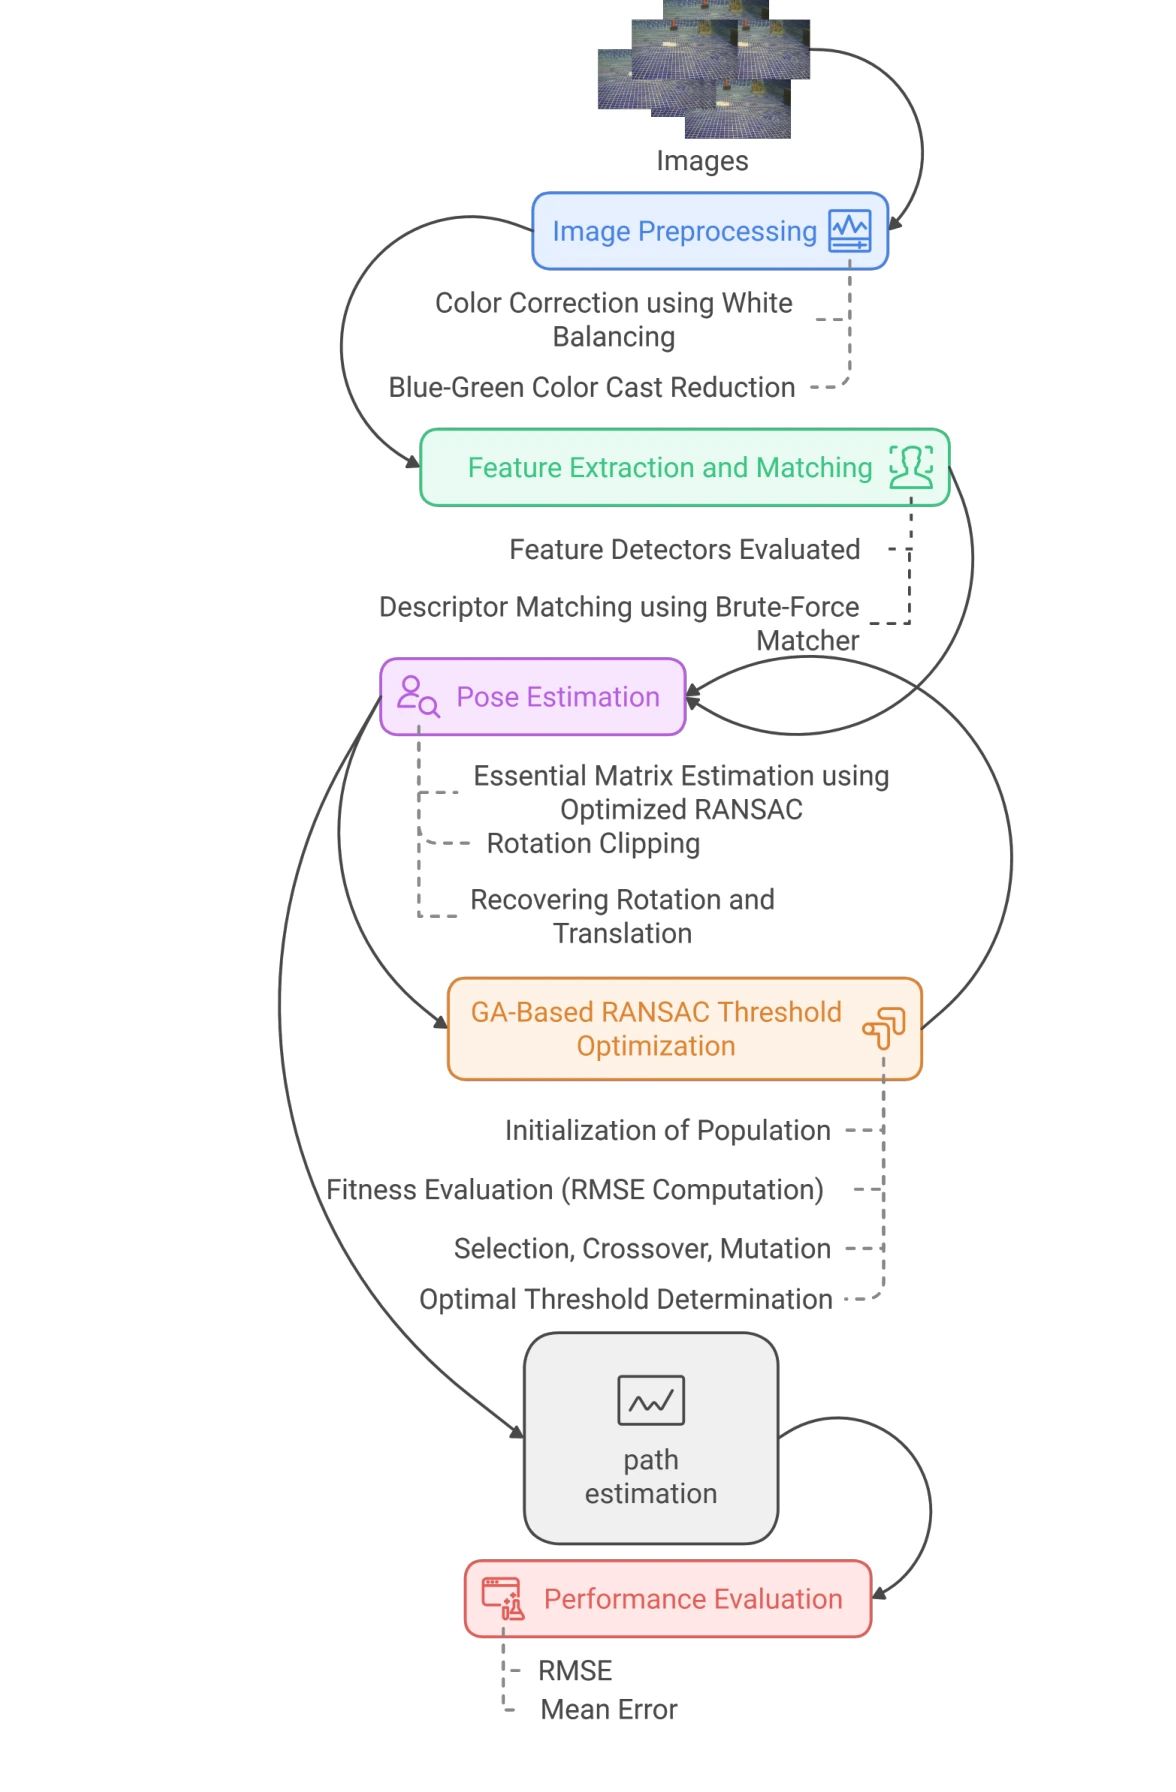 Open figure —
Published SUBVO pipeline, including genetic-algorithm tuning of the RANSAC threshold.
SUBVO Dataset, Fig. 3, p. 3.Results
Reported results
trajectory RMSE
AKAZE; controlled underwater sequence
mean positional error
AKAZE
error standard deviation
AKAZE
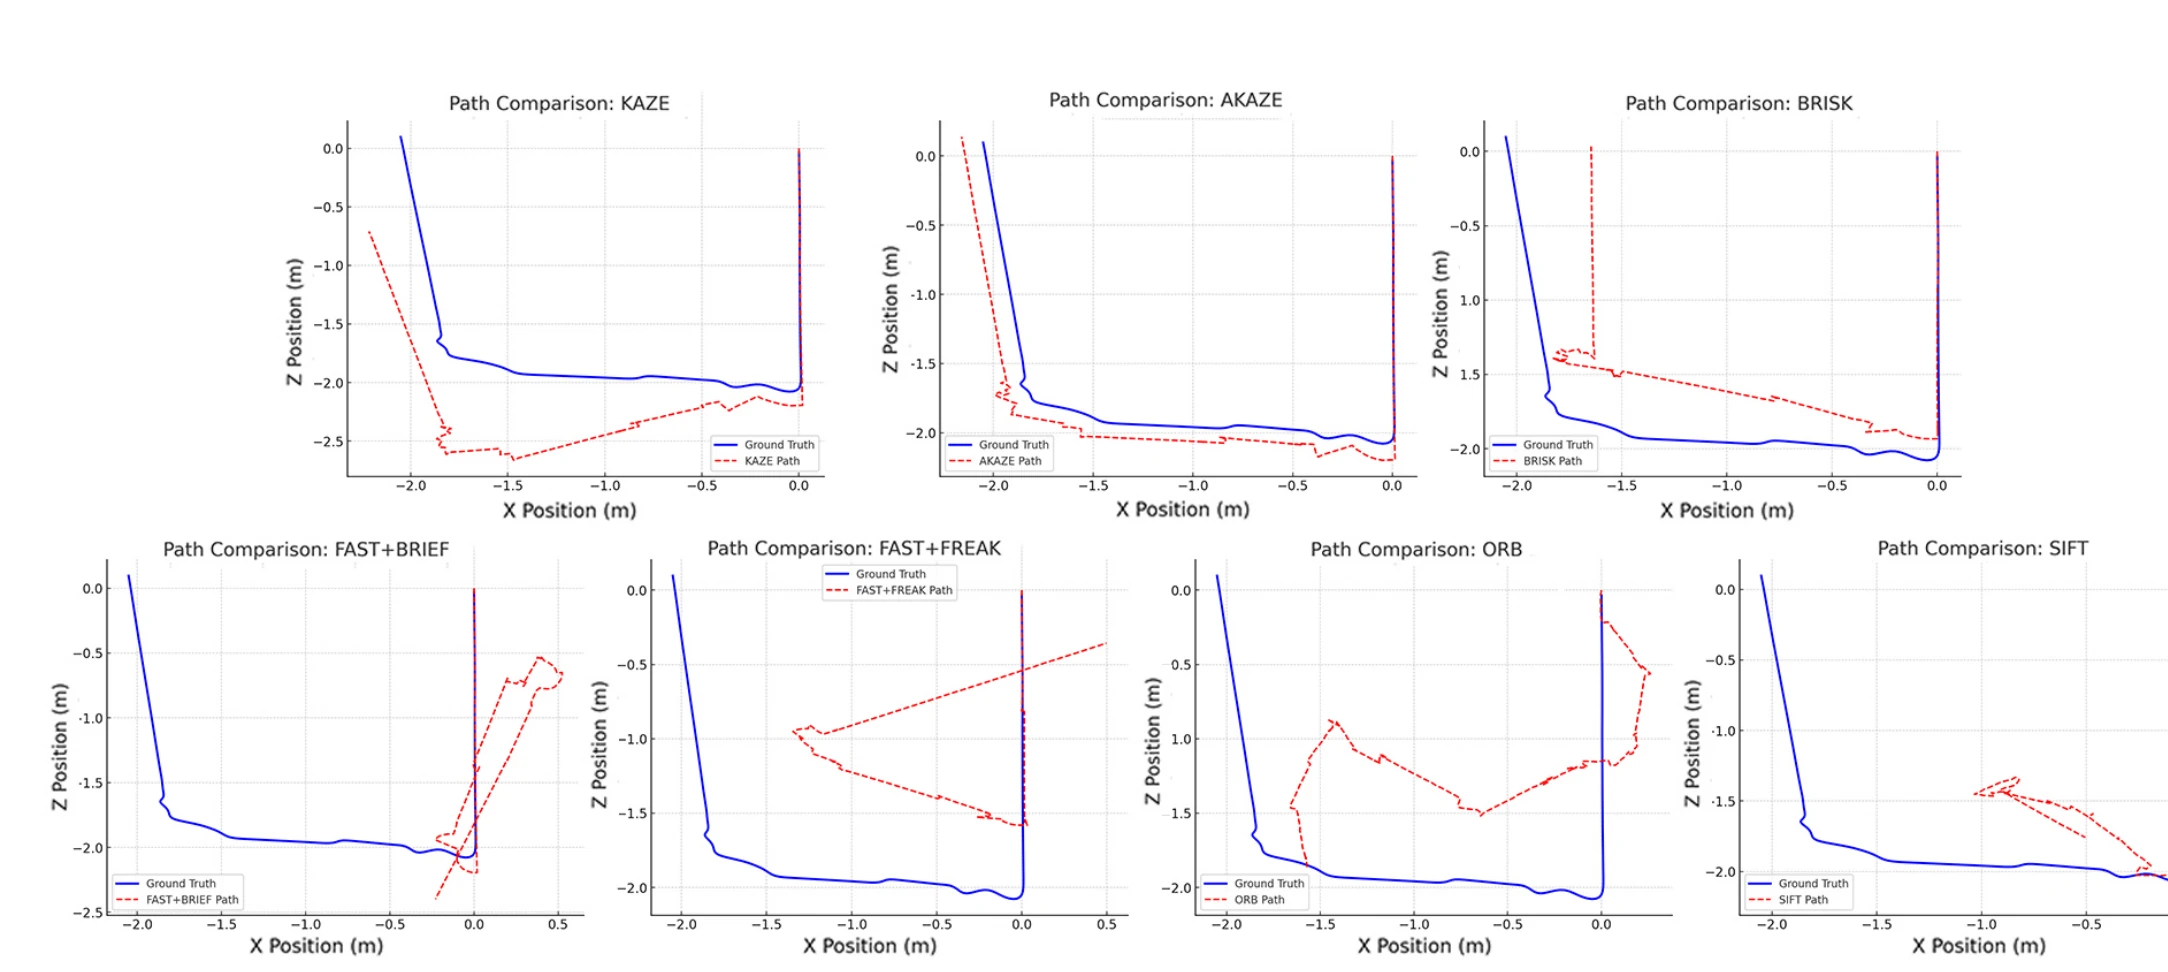
paired comparison
AKAZE vs each alternative method
 Open figure —
Estimated paths for the evaluated feature detectors against the measured reference path.
SUBVO Dataset, Fig. 4, p. 4.Validation & uncertainty
Reference and uncertainty checks
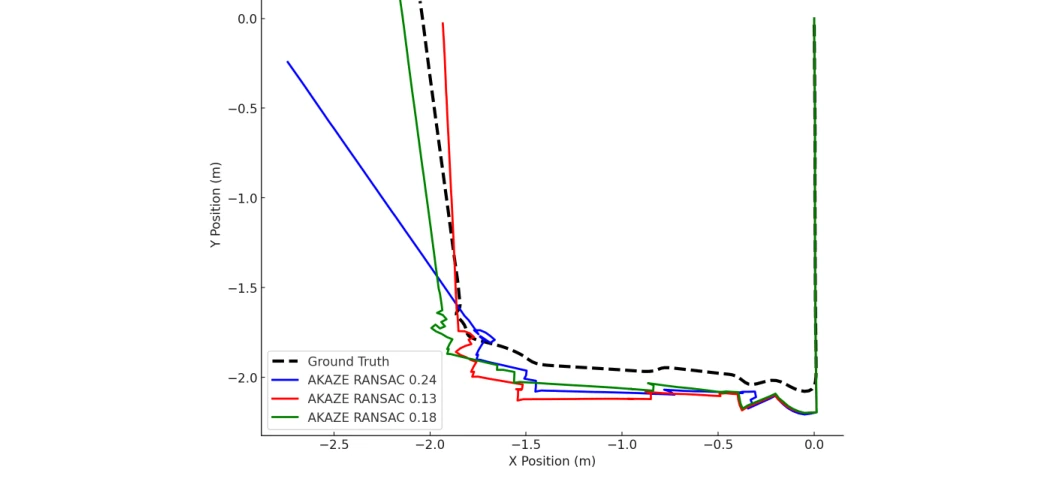
Feature pipelines were evaluated against the measured X-Z path. The reported best trajectory error belongs to the controlled sequence and its published processing configuration.
 Open figure —
RANSAC-threshold comparison; the reported 0.18 setting produces the lowest trajectory RMSE in this sequence.
SUBVO Dataset, Fig. 5, p. 5.Limitations & failure modes
Operating limits and failure modes
 Open figure —
A raw frame from the public calibrated dataset.
SUBVO repository, CC BY 4.0.Low texture, scattering, color loss, moving caustics, repeated pool geometry, insufficient parallax, and unstable scale can all disrupt monocular pose recovery.
SUBVO is a controlled pool dataset and benchmark. The reported error does not imply equivalent navigation performance in open water, variable turbidity, or arbitrary marine scenes.
Technical stack
Tools selected for the measurement chain
- Python
- OpenCV
- Monocular VO
- Essential matrix
- RANSAC
- Camera calibration
Sources & project links
Papers and code
IEEE I2MTC 2025 paper and CC BY 4.0 repository containing images, calibration, and ground truth.